16.43. multi_stereo
The multi_stereo program runs pairwise stereo on many image pairs, given by a
range of stereo convergence angles or an image overlap list, and fuses the results.
Each tile of each stereo pair is a separate job, and these are run in parallel
over a given number of nodes (if --nodes-list is set) and processes per
node. It is thus a generalization of parallel_stereo
(Section 16.52).
It works with every image and camera type ASP supports, and handles all
parallel_stereo options (via --stereo-options).
16.43.1. DEM vs mesh mode
This program has two modes, set with --mode:
dem_mosaic: pairwise stereo with the given cameras, thenpoint2dem(Section 16.57) per pair, then a DEM mosaic withdem_mosaic(Section 16.20). It can also mosaic the maximum triangulation error (withdem_mosaic --max) and an orthoimage (DRG) at the DEM resolution (withdem_mosaic --first). See--point2dem-options. This works for raw images (aerial frame cameras, Section 8.35) or mapprojected images (for example TGO CaSSIS, Section 16.43.2).mesh: pairwise stereo, thenpc_filter(Section 16.55), then a fused mesh withvoxblox_mesh(Section 16.80). The cameras come from a rig (Section 16.61). This is for robot or Structure-from-Motion data, with no datum. See an example below.
In both modes the image pairs are chosen in one of two mutually exclusive ways: read
from an overlap list (--overlap-list), or auto-determined from a convergence angle
range (--conv-angle-list and --conv-angle-range). See
Section 16.43.4.
In both modes the per-tile work of all pairs are put in a single pool, with the
number of processes per node and threads per pair given by --processes and
--threads. The invocation on a cluster is as for parallel_stereo
(Section 8.22).
16.43.2. DEM mosaic example
An example for aerial images is in Section 8.35.
The example below runs pairwise stereo with mapprojected images (Section 6.1.7), and creates a DEM mosaic, as for CaSSIS data (Section 8.17).
Consider a set of images (here ISIS cubes) with cameras (here CSM .json
cameras, Section 8.12), and a DEM ref.tif to mapproject onto (for CaSSIS a
blurred CTX DEM).
Set a local projection:
proj="+proj=stere +lat_0=18.4 +lon_0=77.5 +R=3396190 +units=m +no_defs"
Mapproject every image at the same resolution (Section 16.42), near the native ground sample distance (for CaSSIS about 4.59 m):
for f in image1 image2 image3; do
  mapproject --tr 4.59 --t_srs "$proj" \
    ref.tif $f.cub $f.json $f.map.tif
done
List the mapprojected images in images.txt (one per line) and their cameras in
cameras.txt (in the same order). Then build the overlap list of pairs to run
stereo on, two columns, the left and right image names as in images.txt:
image1.map.tif image2.map.tif
image2.map.tif image3.map.tif
Note that it is often easier to use the convergence angle list, as shown in Section 8.35, while adjusting for the images being mapprojected.
Set up the stereo and point2dem options:
stereoOpts="--alignment-method none
             --stereo-algorithm asp_mgm
             --subpixel-mode 9"

demOpts="--tr 18 --t_srs '$proj' --errorimage --orthoimage"
Then run stereo and mosaic the DEMs. The DEM is gridded at a coarser resolution than the images (here 18 m):
multi_stereo                     \
  --mode dem_mosaic              \
  --image-list images.txt        \
  --camera-list cameras.txt      \
  --overlap-list overlap.txt     \
  --dem ref.tif                  \
  --nodes-list machines.txt      \
  --processes 4                  \
  --threads 2                    \
  --stereo-options "$stereoOpts" \
  --point2dem-options "$demOpts" \
  --output-prefix stereo_out/run
This writes stereo_out/run-DEM.tif. The output names follow point2dem: the
output prefix plus -DEM.tif. As in stereo_dist (Section 16.72), two
optional products are added by passing the corresponding flag in
--point2dem-options:
--errorimagealso writesstereo_out/run-IntersectionErr.tif, the maximum triangulation error over the pairs (Section 14.6.1), combined withdem_mosaic --max. A useful diagnostic of ray self-consistency.--orthoimage(with no argument, the per-pairL.tifis added automatically) also writesstereo_out/run-DRG.tif, the orthoimage, combined withdem_mosaic --first(the first valid pixel, to avoid smearing seams).
Set the option --nodes-list to run on multiple machines (Section 8.22).
The seed DEM (--dem) is the one the images were mapprojected onto. It is passed to
parallel_stereo as the input DEM for mapprojected stereo. The three steps are
stereo, dem, and fuse (see --first-step and --last-step).
Every per-pair point2dem must land on the same grid, so the DEMs mosaic cleanly.
If both --tr and --t_srs are given in --point2dem-options, they are used
for all pairs. Otherwise the first pair sets the grid (its resolution and projection)
and the rest reuse it. The projection can also come from the seed DEM --dem.
A per-pair DEM is dropped from the mosaic when its mean elevation departs from the
seed DEM (--dem) over the same footprint by more than --blunder-tol (in
meters). This removes stereo blunders while keeping real terrain.
16.43.3. Mesh example
Here we will create a mesh of a small portion of the International Space Station (ISS), based on images acquired with the Astrobee robot (later this example will be expanded to a full module).
In this example it is very important to choose for pairwise stereo
images with a convergence angle of about 5-10 degrees. A smaller
convergence angle results in unreliable depth determination, while for
a bigger one the scene changes enough sometimes that stereo
correlation can be erroneous, resulting in artifacts. Note that
rig_calibrator (as well as bundle_adjust and
parallel_stereo) compute the convergence angles.
Then, pc_filter was used for filtering blunders according
to many geometric criteria.
The 7-image dataset used below, the full recipe, and output mesh, are available for download.
See another example in Section 10.3. That one runs stereo on pairs of images created with a stereo rig onboard the MSL Curiosity rover.
16.43.3.1. Creation of camera models
We follow the approach in Section 16.61, but with a rig consisting of just one camera.
The camera intrinsics and the images are used to find the camera poses:
theia_sfm --rig-config camera_config.txt \
  --images 'images/nav_cam/*jpg'         \
  --out-dir theia_out
Note that the images are stored in the nav_cam subdirectory, and
each image name consists of a number and an image extension, following
the conventions used by rig_calibrator, even though here we have
just a single sensor acquiring all images.
Next is refinement of camera poses and registration to world coordinates (this requires first manually picking some features with known 3D positions in the images, per Section 16.61.11):
rig_calibrator                      \
  --rig-config camera_config.txt    \
  --nvm theia_out/cameras.nvm       \
  --camera-poses-to-float "nav_cam" \
  --intrinsics-to-float ""          \
  --num-iterations 100              \
  --num-passes 2                    \
  --num-overlaps 10                 \
  --registration                    \
  --hugin-file control_points.pto   \
  --xyz-file xyz.txt                \
  --out-dir rig_out
Registration to world coordinates is optional. It is still suggested to use at least some rough guesses for where the world positions of some points are. The camera configuration will not be deformed in order to fit precisely the measurements; a single best-fit similarity transform will be applied to the whole setup.
16.43.3.2. Running stereo and mesh creation
As mentioned earlier, the geometry of the scene being imaged requires some careful choices of parameters for stereo. Then, this tool calls several other tools under the hood, so options for those should be set as well. Here’s a recipe which works reasonably well:
maxDistanceFromCamera=3.0

stereoOpts="
  --stereo-algorithm asp_mgm
  --alignment-method affineepipolar
  --ip-per-image 10000
  --min-triangulation-angle 0.5
  --global-alignment-threshold 5
  --session nadirpinhole
  --no-datum
  --corr-seed-mode 1
  --max-disp-spread 300
  --ip-inlier-factor 0.4
  --nodata-value 0"

pc_filter_opts="
  --max-camera-ray-to-surface-normal-angle 75
  --max-valid-triangulation-error 0.0025
  --max-distance-from-camera $maxDistanceFromCamera
  --blending-dist 50 --blending-power 1"

mesh_gen_opts="
  --min_ray_length 0.1
  --max_ray_length $maxDistanceFromCamera
  --voxel_size 0.01"

multi_stereo                            \
  --mode mesh                           \
  --rig-config rig_out/rig_config.txt   \
  --camera-poses rig_out/cameras.txt    \
  --overlap-list overlap.txt            \
  --undistorted-crop-win '1100 700'     \
  --rig-sensor nav_cam                  \
  --first-step stereo                   \
  --last-step  mesh_gen                 \
  --stereo-options "$stereoOpts"        \
  --pc-filter-options "$pc_filter_opts" \
  --mesh-gen-options "$mesh_gen_opts"   \
  --output-prefix stereo_out/run
The overlap list has one image pair per line, with two columns, giving the left and
right image names as in --camera-poses:
image1.tif image2.tif
image2.tif image3.tif
To run stereo between each image and the next one, list the consecutive pairs.
The surface resolution of the cameras is on the order of 1 mm (0.001
meters), the camera is about 1-3 meters from the surface, hence a good
value for the triangulation error was about 0.0025 meters, and the
points in the cloud were binned (before meshing) into voxels of size
0.005 meters. Later some of these choices will be automated, or
scale-independent parameters will be provided. The value
--max-disp-spread 300 is about right for this case, but should
normally be omitted as sometimes it may restrict the disparity
unnecessarily.
There are three steps happening above, namely:
stereo: Runs
parallel_stereo(Section 16.52) and writes a point cloud in .tif format for each pair in the overlap list. This is the most time-consuming step.pc_filter: For each point cloud runs
pc_filter(Section 16.55) and writes filtered point clouds in .tif and .pcd formats, and a textured mesh for that run in .obj format. The .pcd file is in left camera’s coordinates. The .obj file is for individual stereo run inspection purposes.mesh_gen: Use
voxblox_mesh(Section 16.80) to fuse the filtered point clouds in .pcd format and create a mesh in .ply format.
The images are undistorted internally before stereo is run. (The undistortion step may be optional in future versions.)
See --first-step and --last-step in
Section 16.43.4 for how to choose which processing
steps to run.
16.43.3.3. Creating a textured mesh
The obtained mesh can be post-processed (smoothed, hole-filled, etc.)
using a handful of CGAL-based tools shipped with ASP
(Section 16.13). Then, it can be textured with the original
images using the texrecon tool (Section 16.76) as:
texrecon --rig-config rig_out/rig_config.txt \
  --camera-poses rig_out/cameras.txt         \
  --mesh stereo_out/run-fused_mesh.ply       \
  --rig-sensor nav_cam                       \
  --undistorted-crop-win '1100 700'          \
  --out-dir stereo_out
This produces stereo_out/nav_cam/texture.obj.
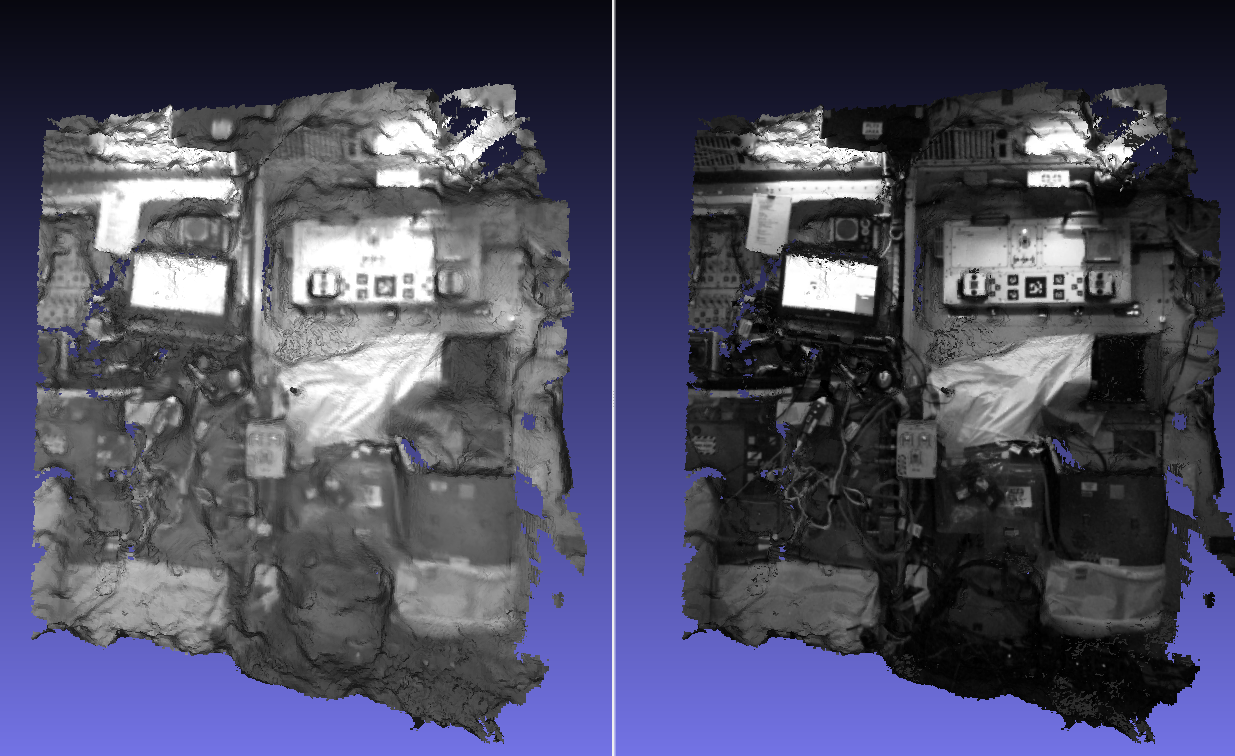
Fig. 16.23 Fused .ply mesh and textured .obj file produced by voxblox_mesh
and texrecon (left and right). Here, no smoothing or hole-filling
of the meshes was used (Section 16.13). See Section 10.2
for an example of mesh and texture creation for depth data.
16.43.3.4. Handling issues
If the produced mesh is noisy, it is suggested to inspect individual
.obj files produced by each stereo pair, the triangulation error of
each filtered point cloud (fourth band, extractable with
gdal_translate -b 4), and the blending weight files saved by
pc_filter.
One may need to decrease the value of
--max-valid-triangulation-error, use less of the boundary image
region (--undistorted-crop-win) or redo the bundle adjustment with
rig_calibrator.
16.43.4. Command-line options for multi_stereo
- --mode <string (default: “”)>
Processing mode. One of:
mesh(pairwise stereo,pc_filter, then a fused mesh, with rig cameras) ordem_mosaic(pairwise stereo with the given cameras, per-pairpoint2dem, then a DEM mosaic, and optionally a triangulation error and orthoimage mosaic). Required.- --overlap-list <string (default: “”)>
Text file with the image pairs to run stereo on, one pair per line, two columns,
left_image right_image. For modemeshthe names are as in--camera-poses. For modedem_mosaicas in--image-list(the cameras come from--image-listand--camera-list). Lines starting with a pound character are ignored. Mutually exclusive with--conv-angle-list.- --conv-angle-list <string (default: “”)>
A
bundle_adjustconvergence angle report, named<prefix>-convergence_angles.txt(Section 16.5.11.4). The overlap list is built automatically from it: each image pair whose median convergence angle is within--conv-angle-rangeis used. An alternative to--overlap-listfor choosing the pairs, in both modes. The report may name the--image-listimages, or the images they were mapprojected from (Section 6.1.7). Mutually exclusive with--overlap-list. See the example in Section 8.35.- --conv-angle-range <min,max>
Two comma-separated values, no quotes, the minimum and maximum median convergence angle in degrees, for example
15,45. Used with--conv-angle-listto select the stereo pairs.- --output-prefix <string (default: “”)>
The output prefix, as for parallel_stereo and stereo_dist. The DEM mosaic, mesh, per-pair stereo data, and other outputs are named starting with this prefix (for example <prefix>-DEM.tif, <prefix>-fused_mesh.ply).
- --stereo-options <string (default: “”)>
Options to pass to
parallel_stereo. Use double quotes around the full list and simple quotes if needed by an individual option, or vice-versa.- --processes <integer (default: 1)>
The width of the parallel job: how many per-tile stereo jobs run at once, pooled over all pairs (both modes). If
--nodes-listorPBS_NODEFILEis set, the pool is spread over those nodes.- --threads <integer (default: 0)>
Threads per
parallel_stereopair. If positive, each pair is run with--threads-multiprocessand--threads-singleprocessset to this. Default: letparallel_stereodecide.- --nodes-list <filename (default: “”)>
A file with the computing nodes, one per line, over which to spread the pooled stereo jobs, as for
parallel_stereoandstereo_dist. The nodes must share a file system. Default: the value of$PBS_NODEFILE, if set.- --first-step <string (default: “stereo”)>
Let the first step run by this tool be, for mode
mesh:stereo,pc_filter, ormesh_gen; for modedem_mosaic:stereo,dem, orfuse. This allows resuming a run at a desired step.- --last-step <string (default: “”)>
The last step run by this tool. See
--first-stepfor allowed values. Default: the last step of the mode.
Options for mode mesh:
- --rig-config <string (default: “”)>
Rig configuration file.
- --rig-sensor <string (default: “”)>
Which rig sensor images to use. Must be among the sensors specified via
--rig-config. To use images from several sensors, pass in a quoted list of them, separated by a space.- --camera-poses <string (default: “”)>
Read images and camera poses for this sensor from this list.
- --undistorted-crop-win <string (default: “”)>
The dimensions of the central image region to keep after the internal undistortion step and before using it in stereo. Normally 85% - 90% of distorted (actual) image dimensions would do. Suggested the Astrobee images: sci_cam: ‘1250 1000’ nav_cam: ‘1100 776’. haz_cam: ‘250 200’.
- --pc-filter-options <string (default: “”)>
Options to pass to
pc_filter.- --mesh-gen-options <string (default: “”)>
Options to pass to
voxblox_meshfor mesh generation.
Options for mode dem_mosaic:
- --dem <string (default: “”)>
Seed DEM. For mapprojected input images this is the DEM they were mapprojected onto, appended as the trailing positional argument to
parallel_stereo. It is also the blunder-filter reference, and sets the output projection if it is not otherwise given.- --blunder-tol <double (default: 500)>
Blunder filter tolerance, in meters (needs
--dem). A per-pair DEM whose mean elevation departs from the seed DEM (--dem) over its footprint by more than this is dropped.- --point2dem-options <string (default: “”)>
Options for
point2dem. Pass--errorimageto also mosaic the maximum triangulation error, and--orthoimage(with no argument, the per-pairL.tifis added automatically) to also mosaic an orthoimage (DRG), as instereo_dist(Section 16.72). If both--trand--t_srsare given here, they are used for all pairs; otherwise the grid and projection are taken from the first DEM produced and applied to the rest, so all share one grid.- --dem-mosaic-options <string (default: “”)>
Extra options for the
dem_mosaicof the per-pair DEMs.- -h, --help
Show this help message and exit.